Three IoT-connected prototypes bring concealed motion, pursuit, and capture into a compact apartment.
DWG NO.DWG-001
CATEGORYPET · IoT
MATERIALPLA · ELEC.
YEAR2026
SHEET2 / 16
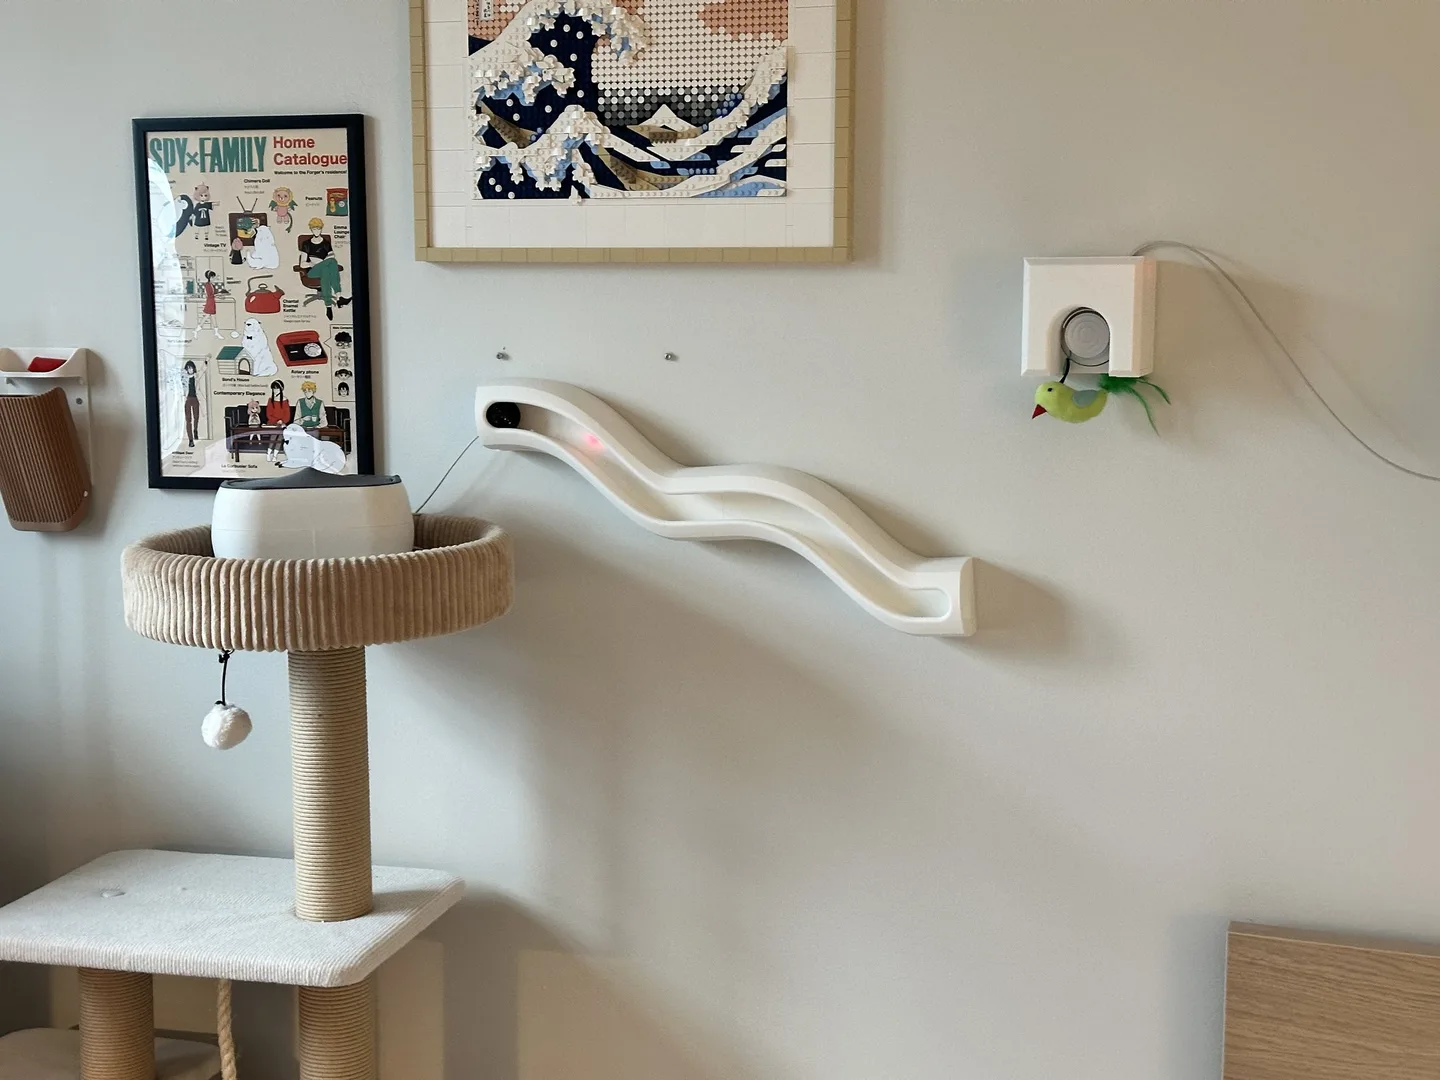
FIG 01 · SYSTEM IN CONTEXT
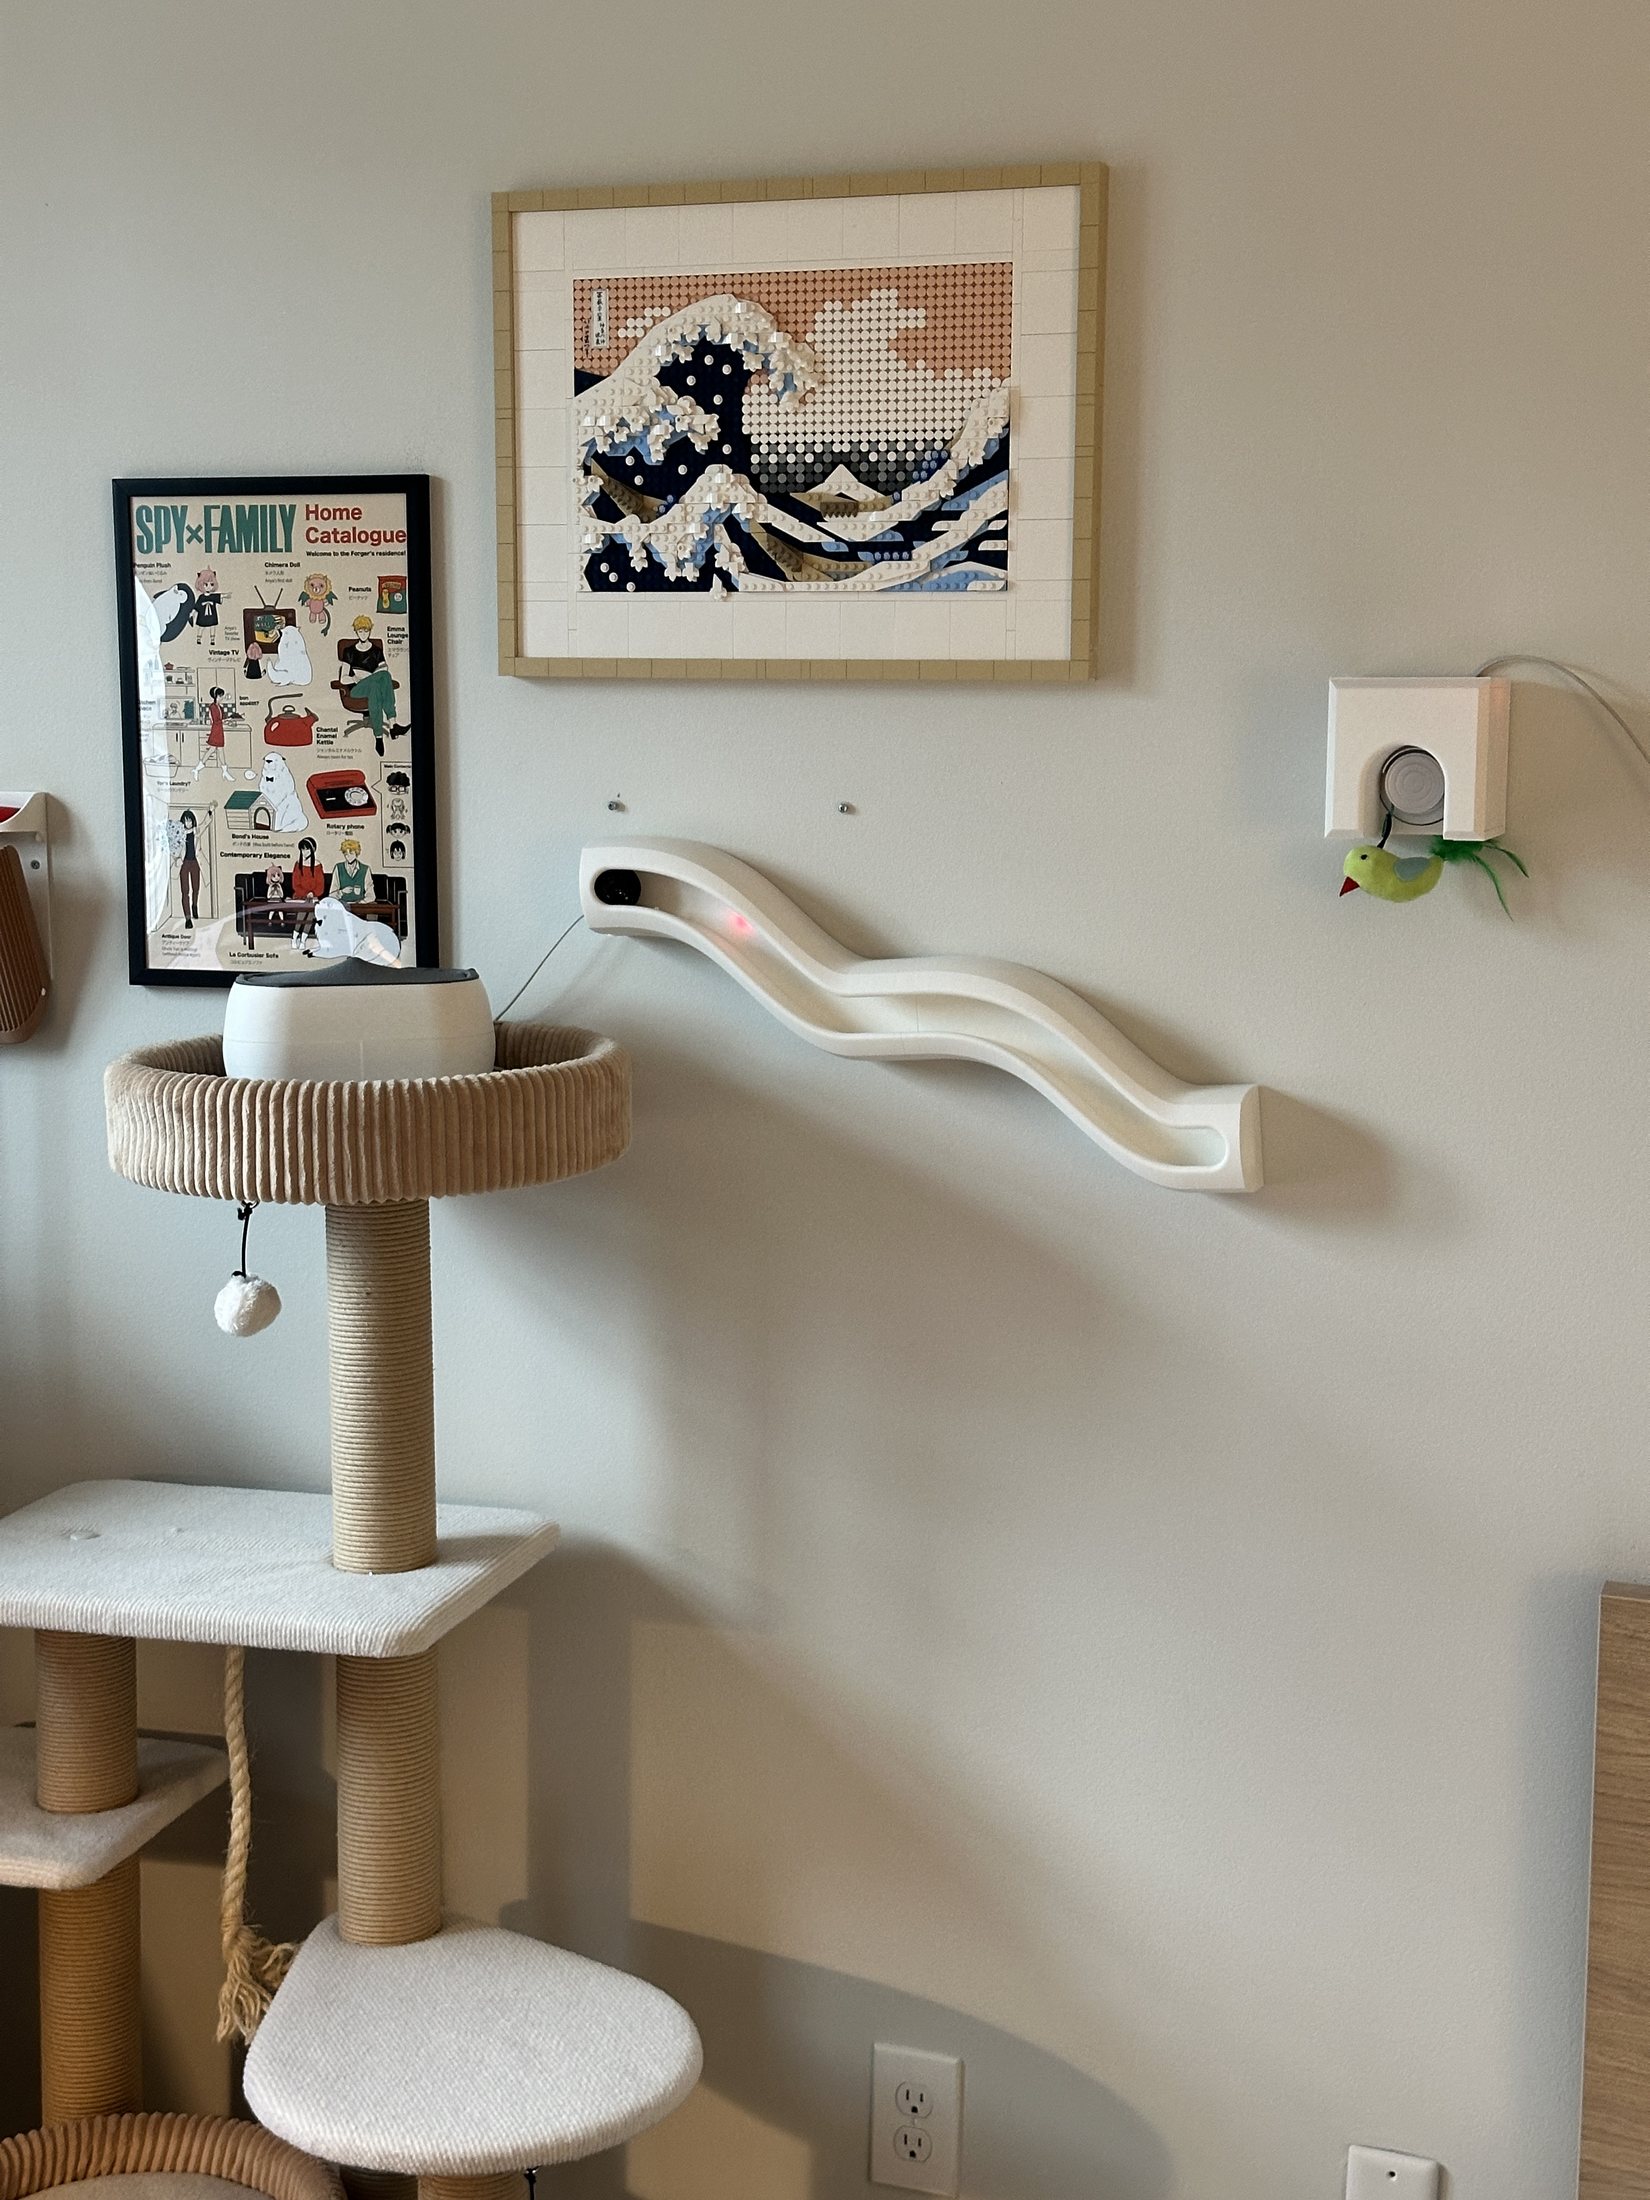
FIG 01 — STIR, CHASE, AND CATCH DISTRIBUTED THROUGH A CAT'S EXISTING VERTICAL TERRITORY
SEC 01
Brief概要
DESIGN QUESTION · 设计问题
How can connected play fit the places a cat already uses at home?
I developed HUNT as three connected prototypes for small urban apartments: concealed movement at the window, a moving target along the wall, and something to catch near the floor. The project brings behavioral research, mechanism design, soft materials, and ESP32 control into one physical system.
COURSEID DESIGN PRINCIPLE II
SYSTEM3 CONNECTED DEVICES
CONTROLESP32 · ESP-NOW · BLYNK
PROCESSRESEARCH · MECHANISMS · CMF
SEC 02
Research to Direction研究转译
CAT + OWNER + APARTMENT
Give each interaction a place in the room.
I compared selected floor toys, connected devices, and wall-mounted cat furniture, including Cheerble M1, Enabot ROLA, Catastrophic Creations, and BENTOPAL. This was an exploratory precedent review, not a representative market survey.
The design brief paired two needs: varied physical play for the cat, and a system the owner could accommodate in a small apartment. That led to three spatially distributed interactions with shared controls.
SPACE → PLACEMENTWINDOW · WALL · FLOOR EDGE
OWNER → CONTROLONE SESSION · ADJUSTABLE TIMING
PLAY → INTERACTIONCONCEALED MOTION · PURSUIT · CAPTURE
SEC 03
Connected Control无线控制
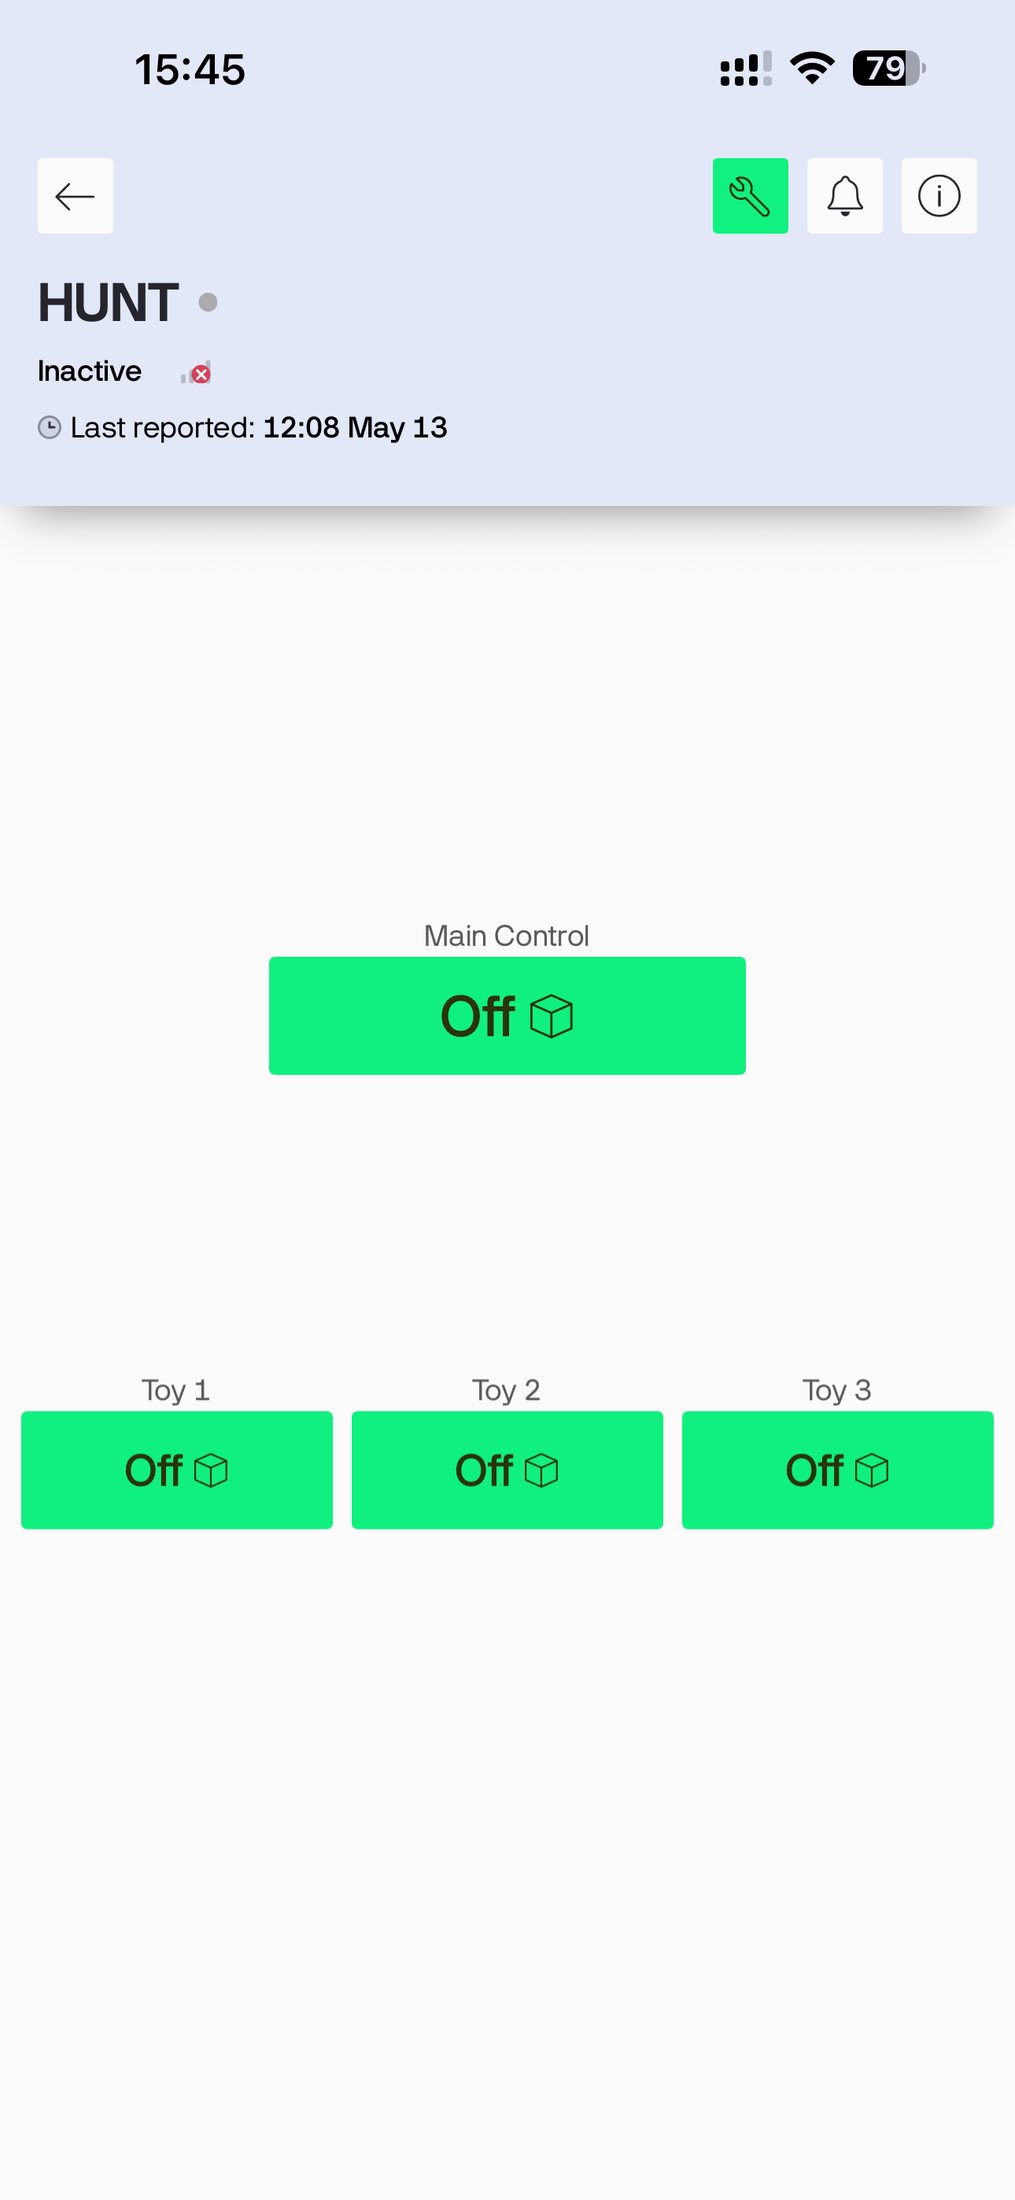
FIG 02 · BLYNK UI
FIG 02 — OWNER CONTROL FOR A FULL SESSION OR INDIVIDUAL DEVICE DEBUGGING
CLOUD CONTROL · LOCAL COORDINATION
One master device schedules the experience; the three objects coordinate directly.
I separated owner control from device coordination. STIR connects to Blynk over Wi-Fi; ESP-NOW links the three ESP32 devices directly. Timing, trigger duration, and sequence order can be adjusted without reflashing the hardware, making the USB-powered prototypes easier to tune during development.
MASTERSTIR · WI-FI / BLYNK
LOCAL LINKESP-NOW PEER-TO-PEER
ADJUSTMENTTIMING · DURATION · SEQUENCE
SEC 04
Three-Device Sequence三段系统
BEHAVIOR → MECHANISM
Three ways to engage with a physical target.
I used spot, stalk, chase, capture, and kill as a design model for the sequence. STIR conceals motion, CHASE exposes a moving target, and CATCH provides graspable prey. The renders show intended form; the printed assemblies and clips show the mechanisms in use.
01 / 03 · WINDOW + SILL
STIR
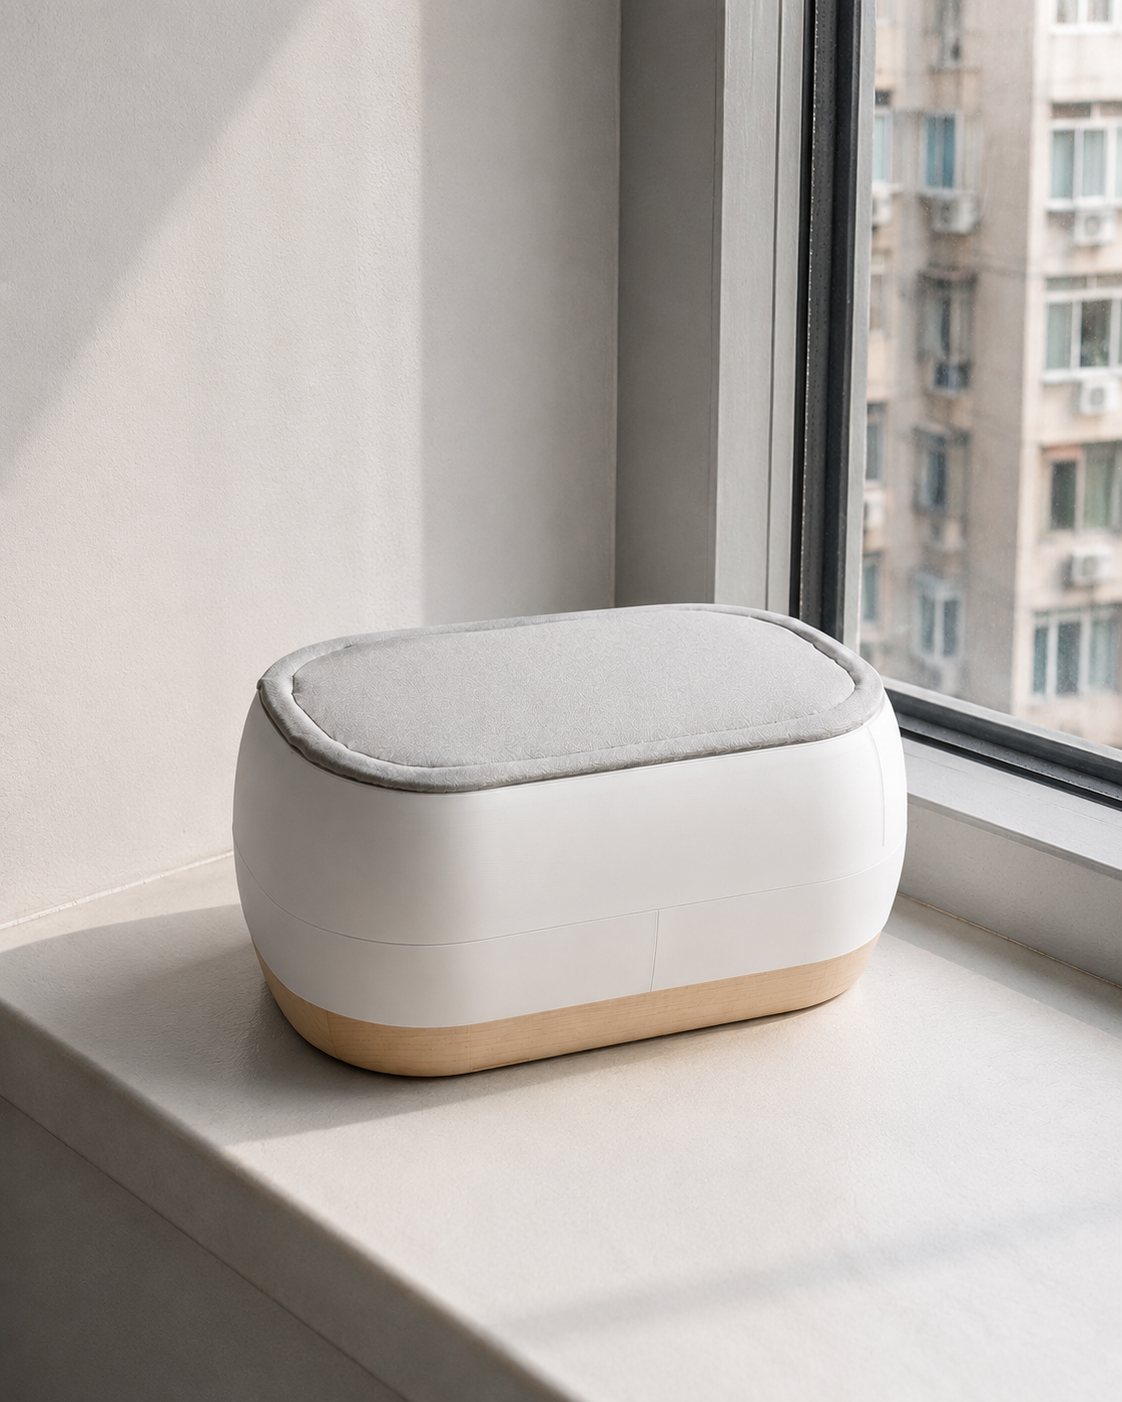
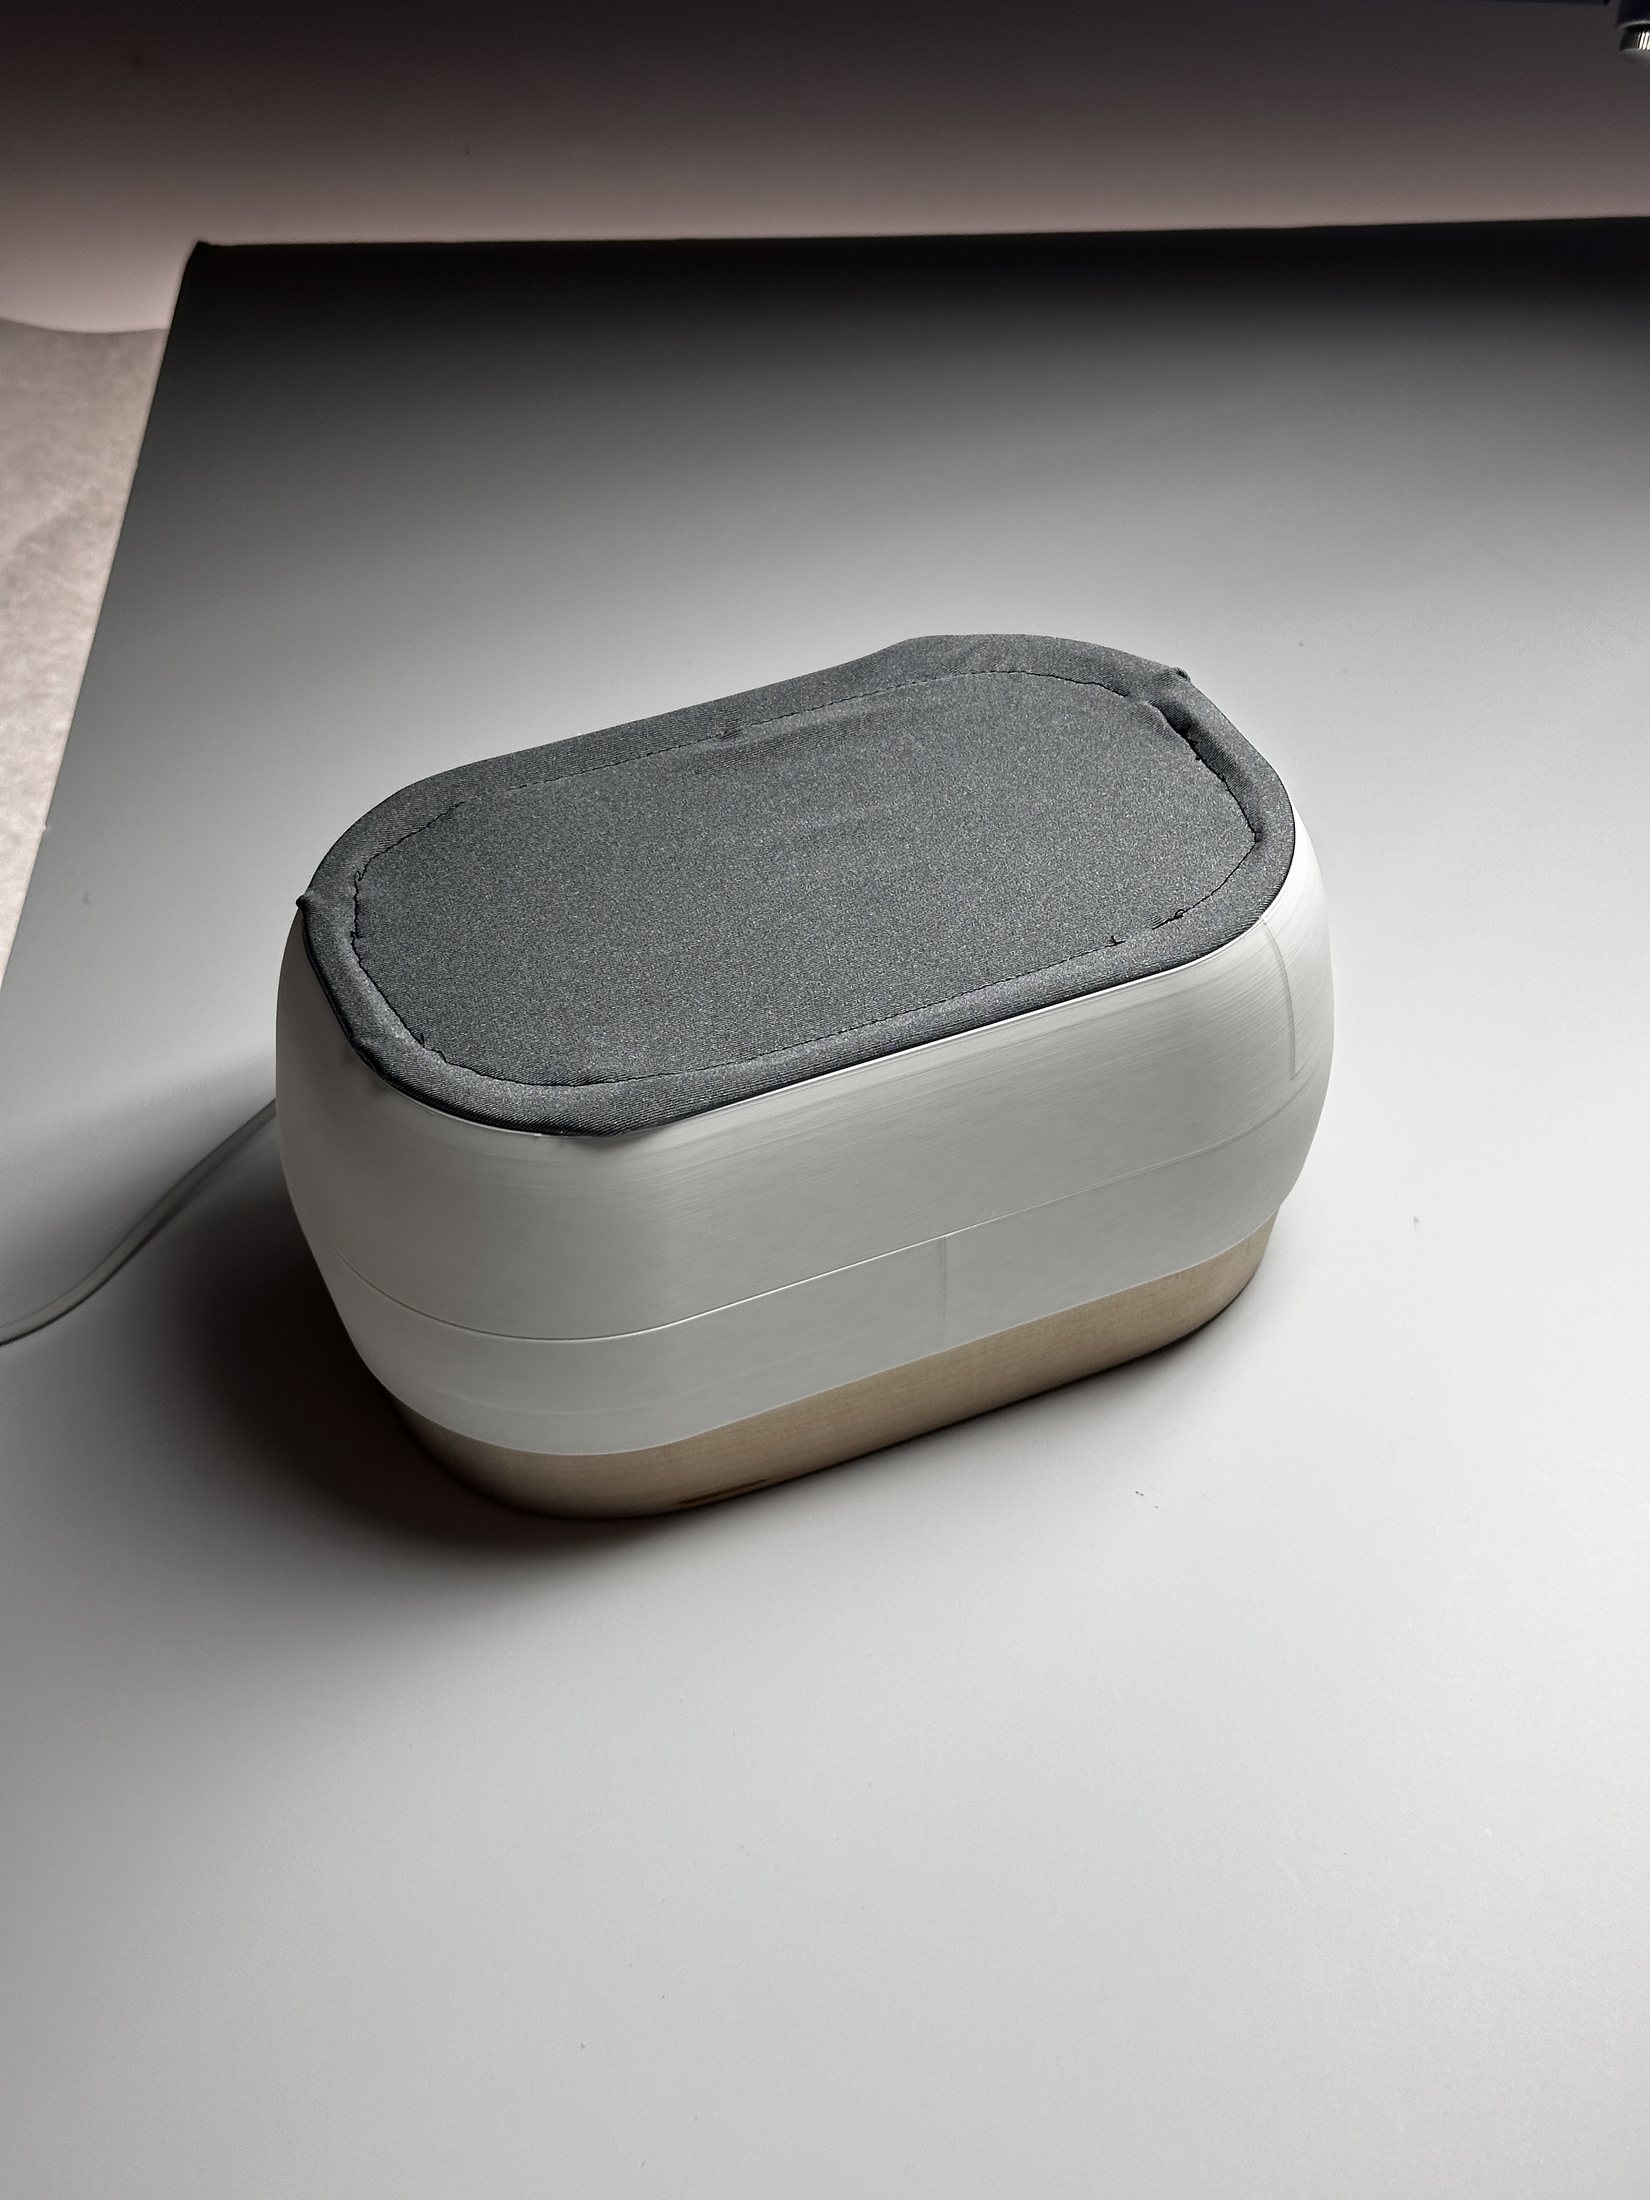
SPOT + STALK I paired a concealed servo arm with a soft spandex cover so movement appears through the surface. The freestanding form places that interaction on a sill or other elevated surface without adhesive installation.
FIG 03 · RENDER
FIG 03 — SOFT-TOP WINDOW MODULE
FIG 04 · PROTOTYPE
FIG 04 — FDM ENCLOSURE + UPHOLSTERED MEMBRANE
FIG 05 · IN USE
FIG 05 — CAT TRACKING CONCEALED MOTION
02 / 03 · MID-WALL
CHASE
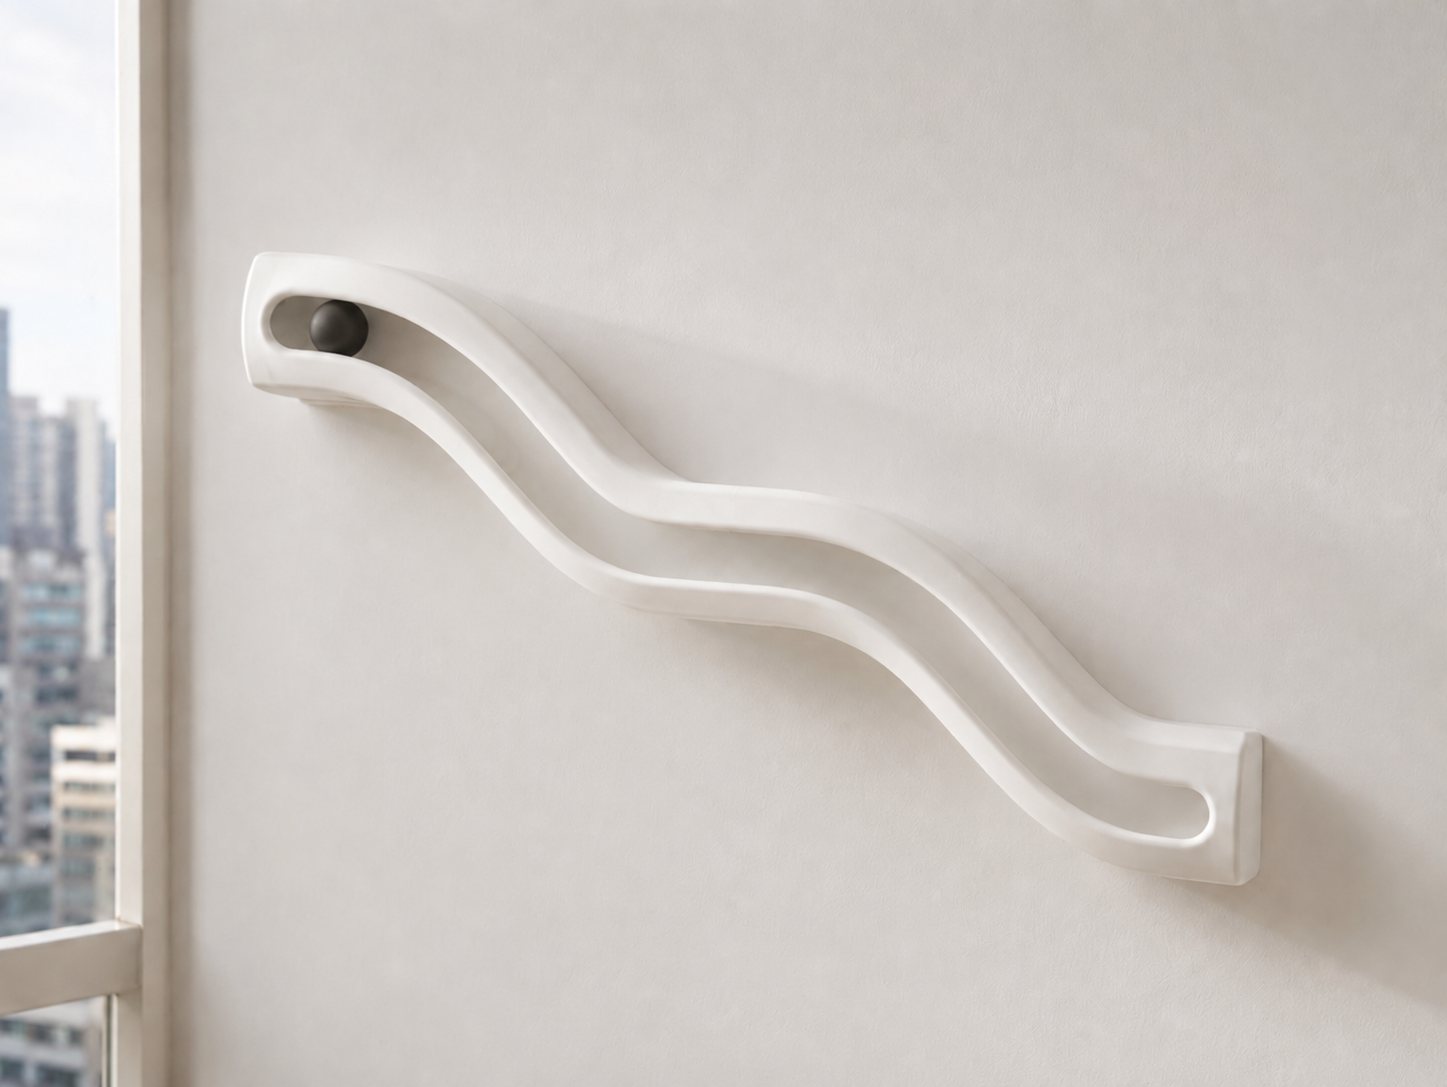
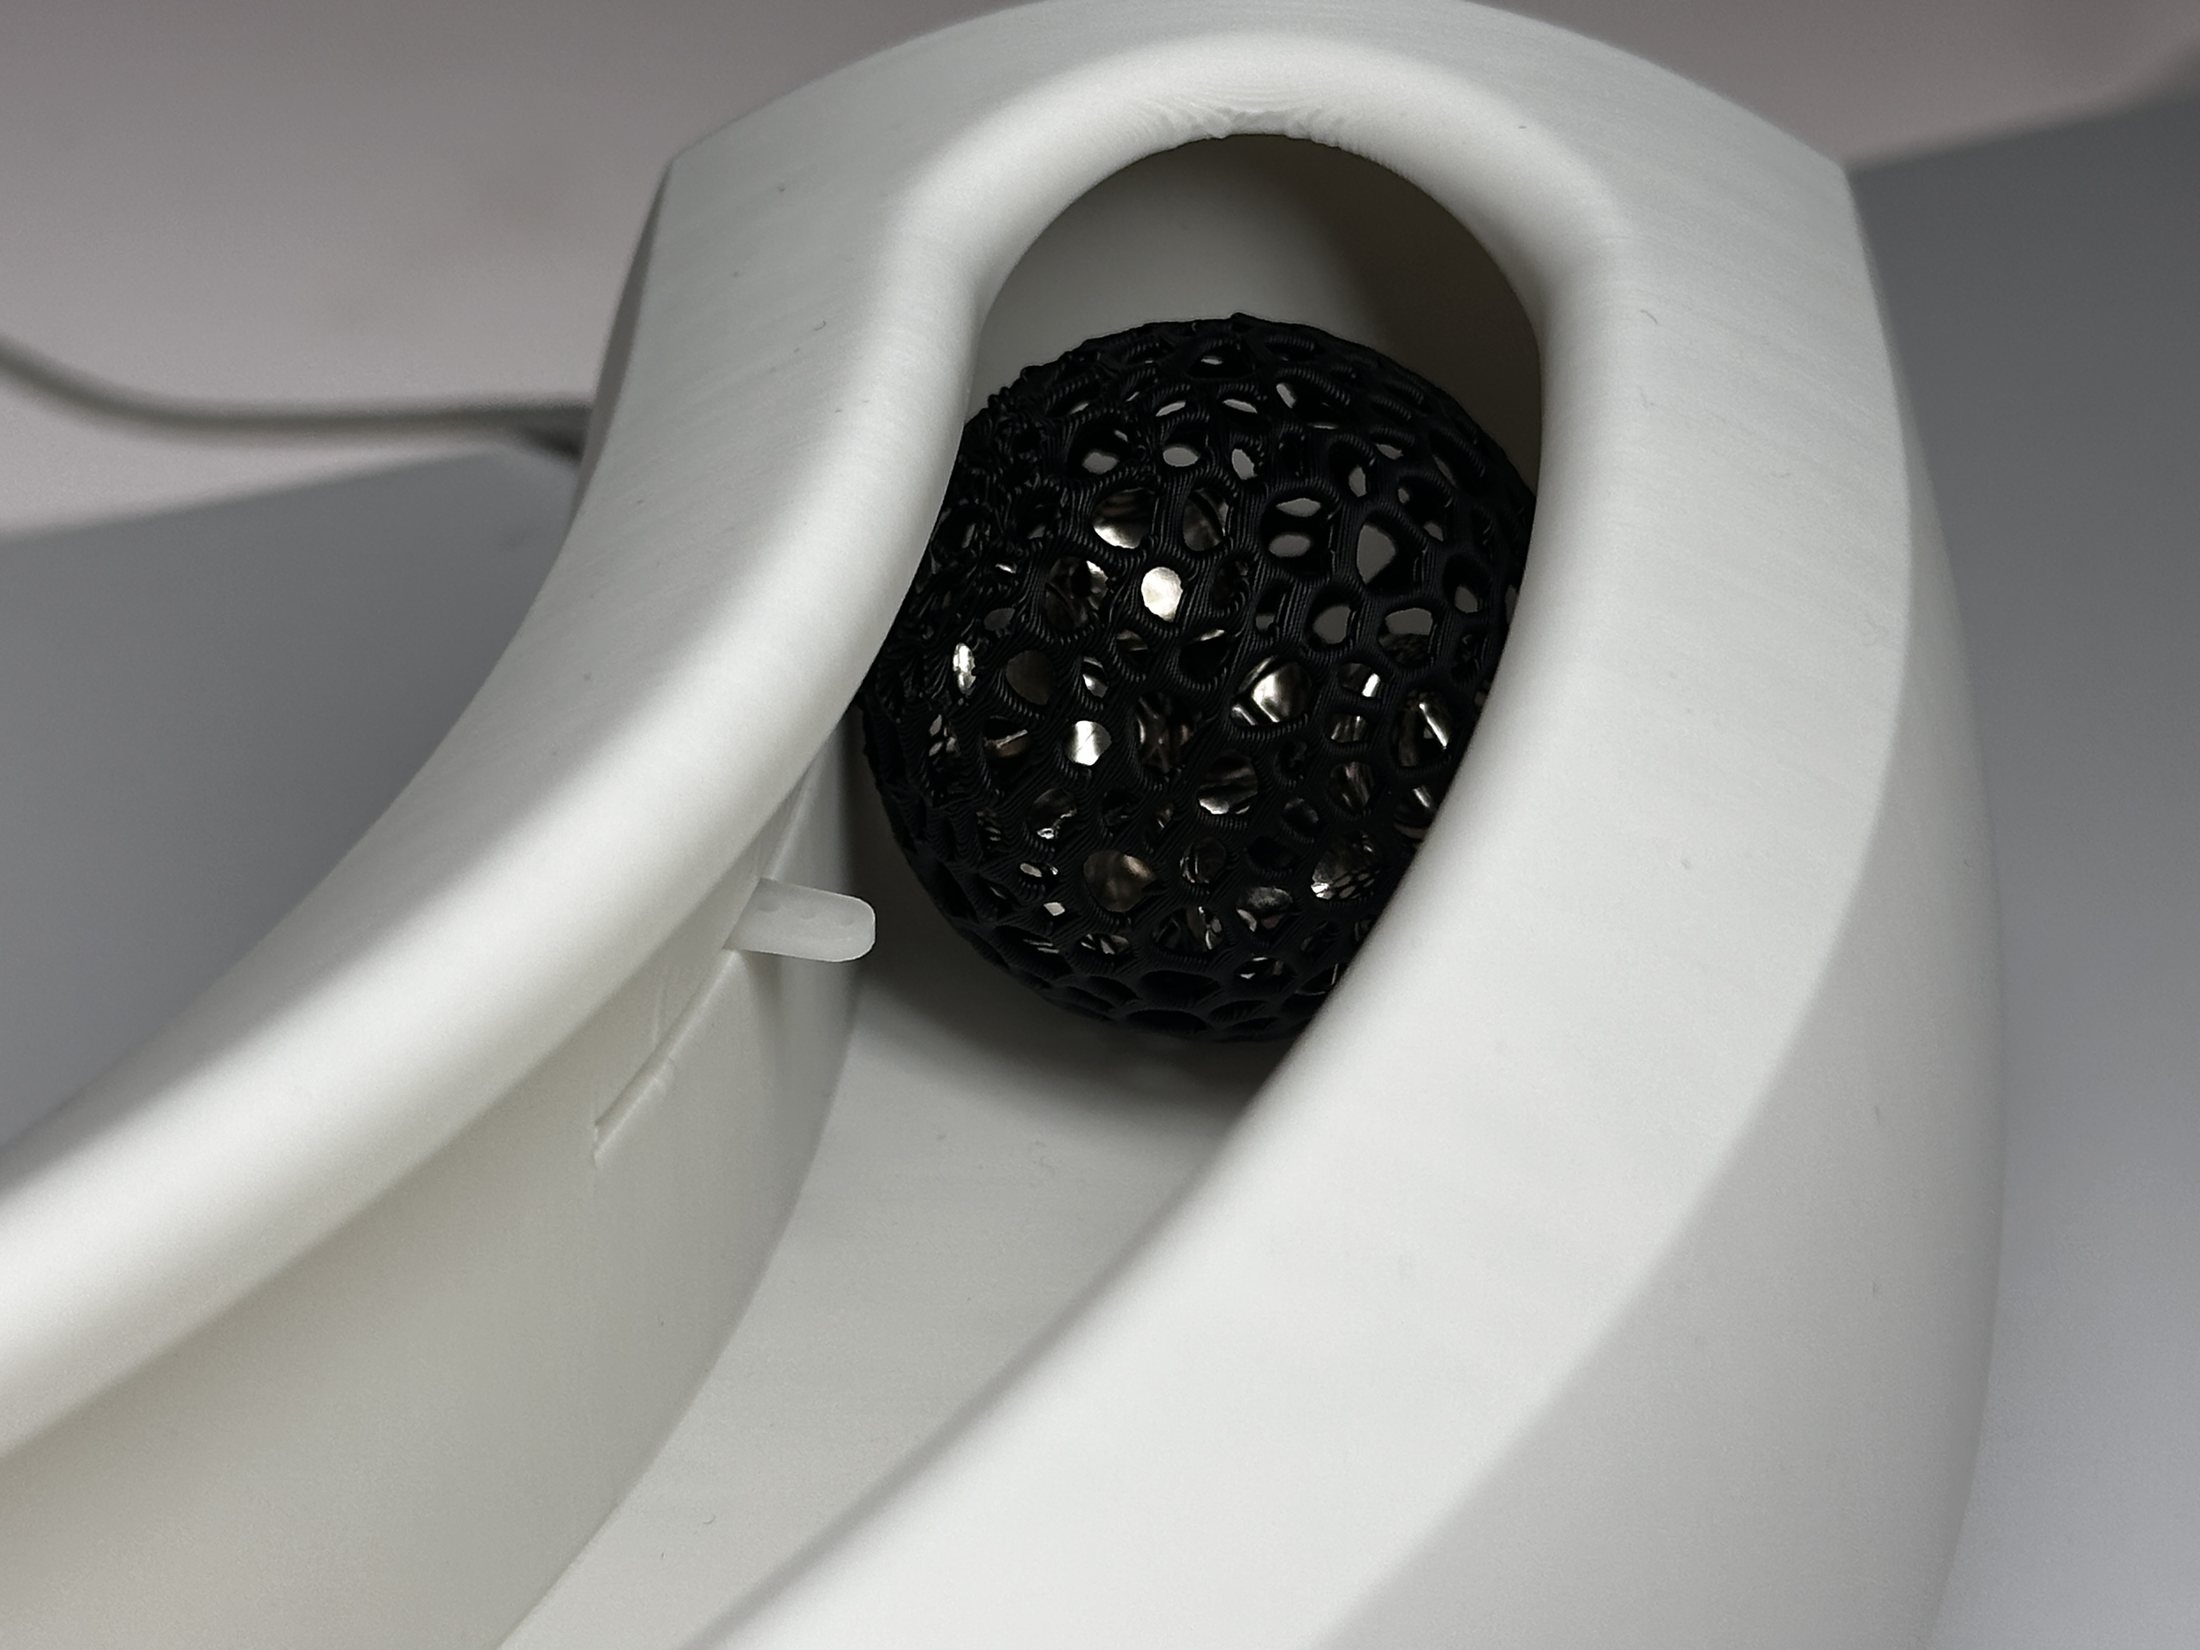
STALK + CHASE A servo latch holds the bell ball at the top of an S-curve. Releasing it lets gravity carry the target along a visible wall path. Command-Strip mounting places the track above the floor without drilling.
FIG 06 · RENDER
FIG 06 — COMMAND-STRIP WALL TRACK · NO DRILLING
FIG 07 · LATCH
FIG 07 — SERVO LATCH HOLDS AND RELEASES THE BELL BALL
FIG 08 · IN USE
FIG 08 — FAST WALL-LEVEL TARGET MOTION
03 / 03 · FLOOR-ADJACENT
CATCH
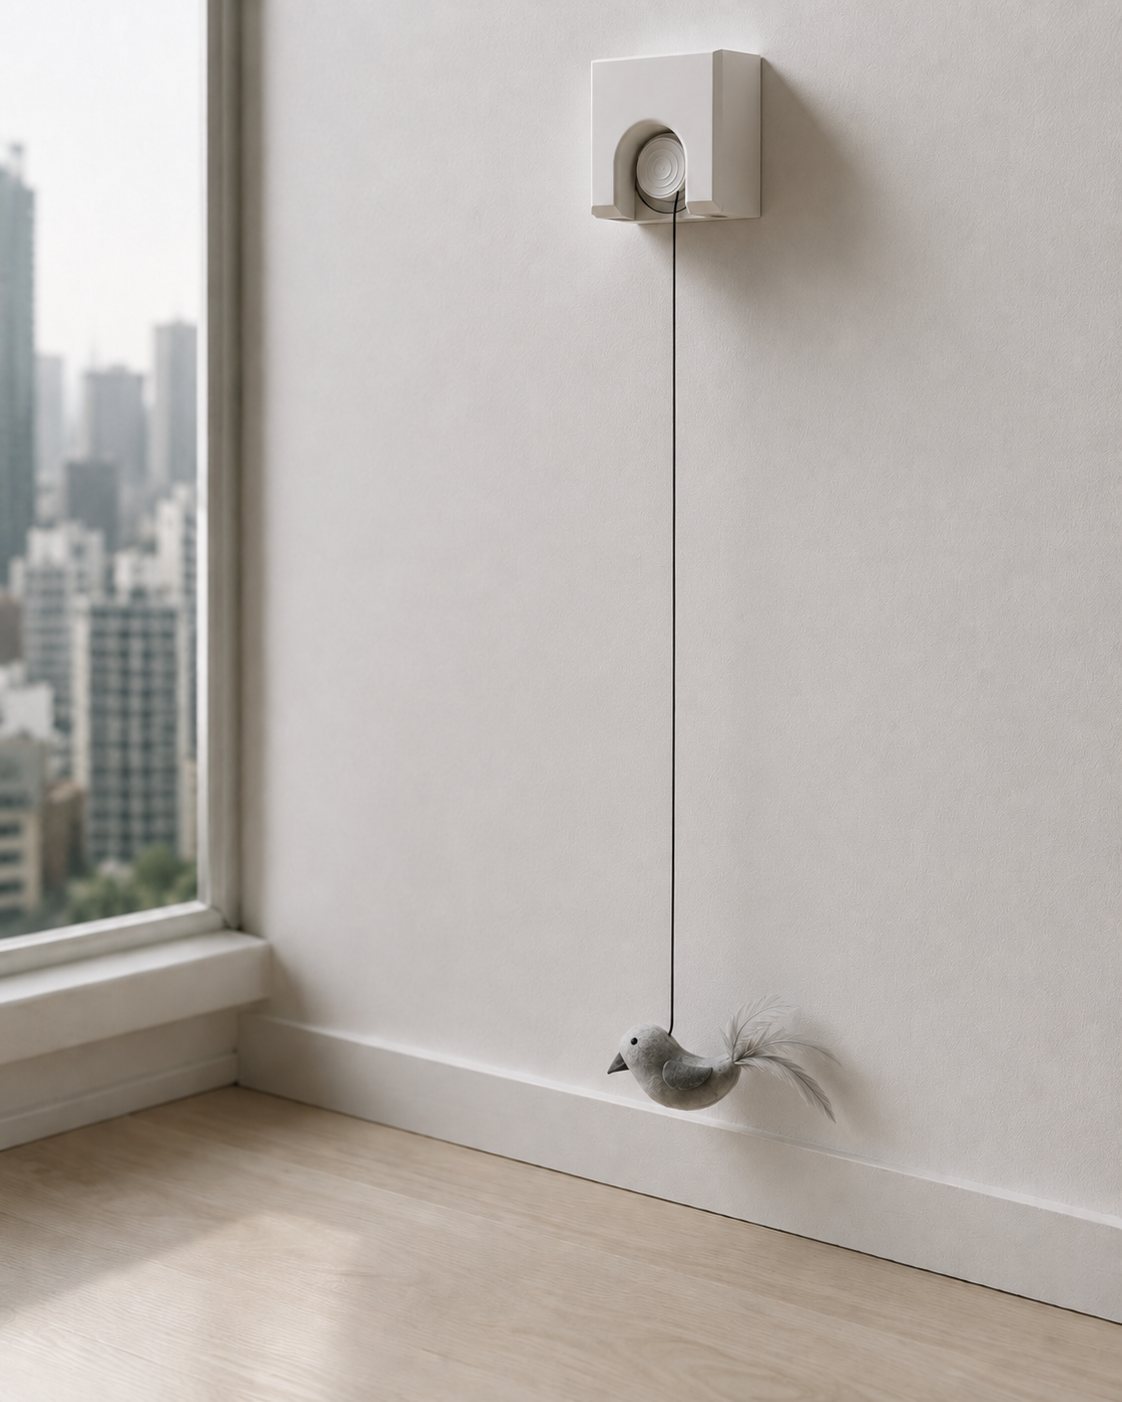
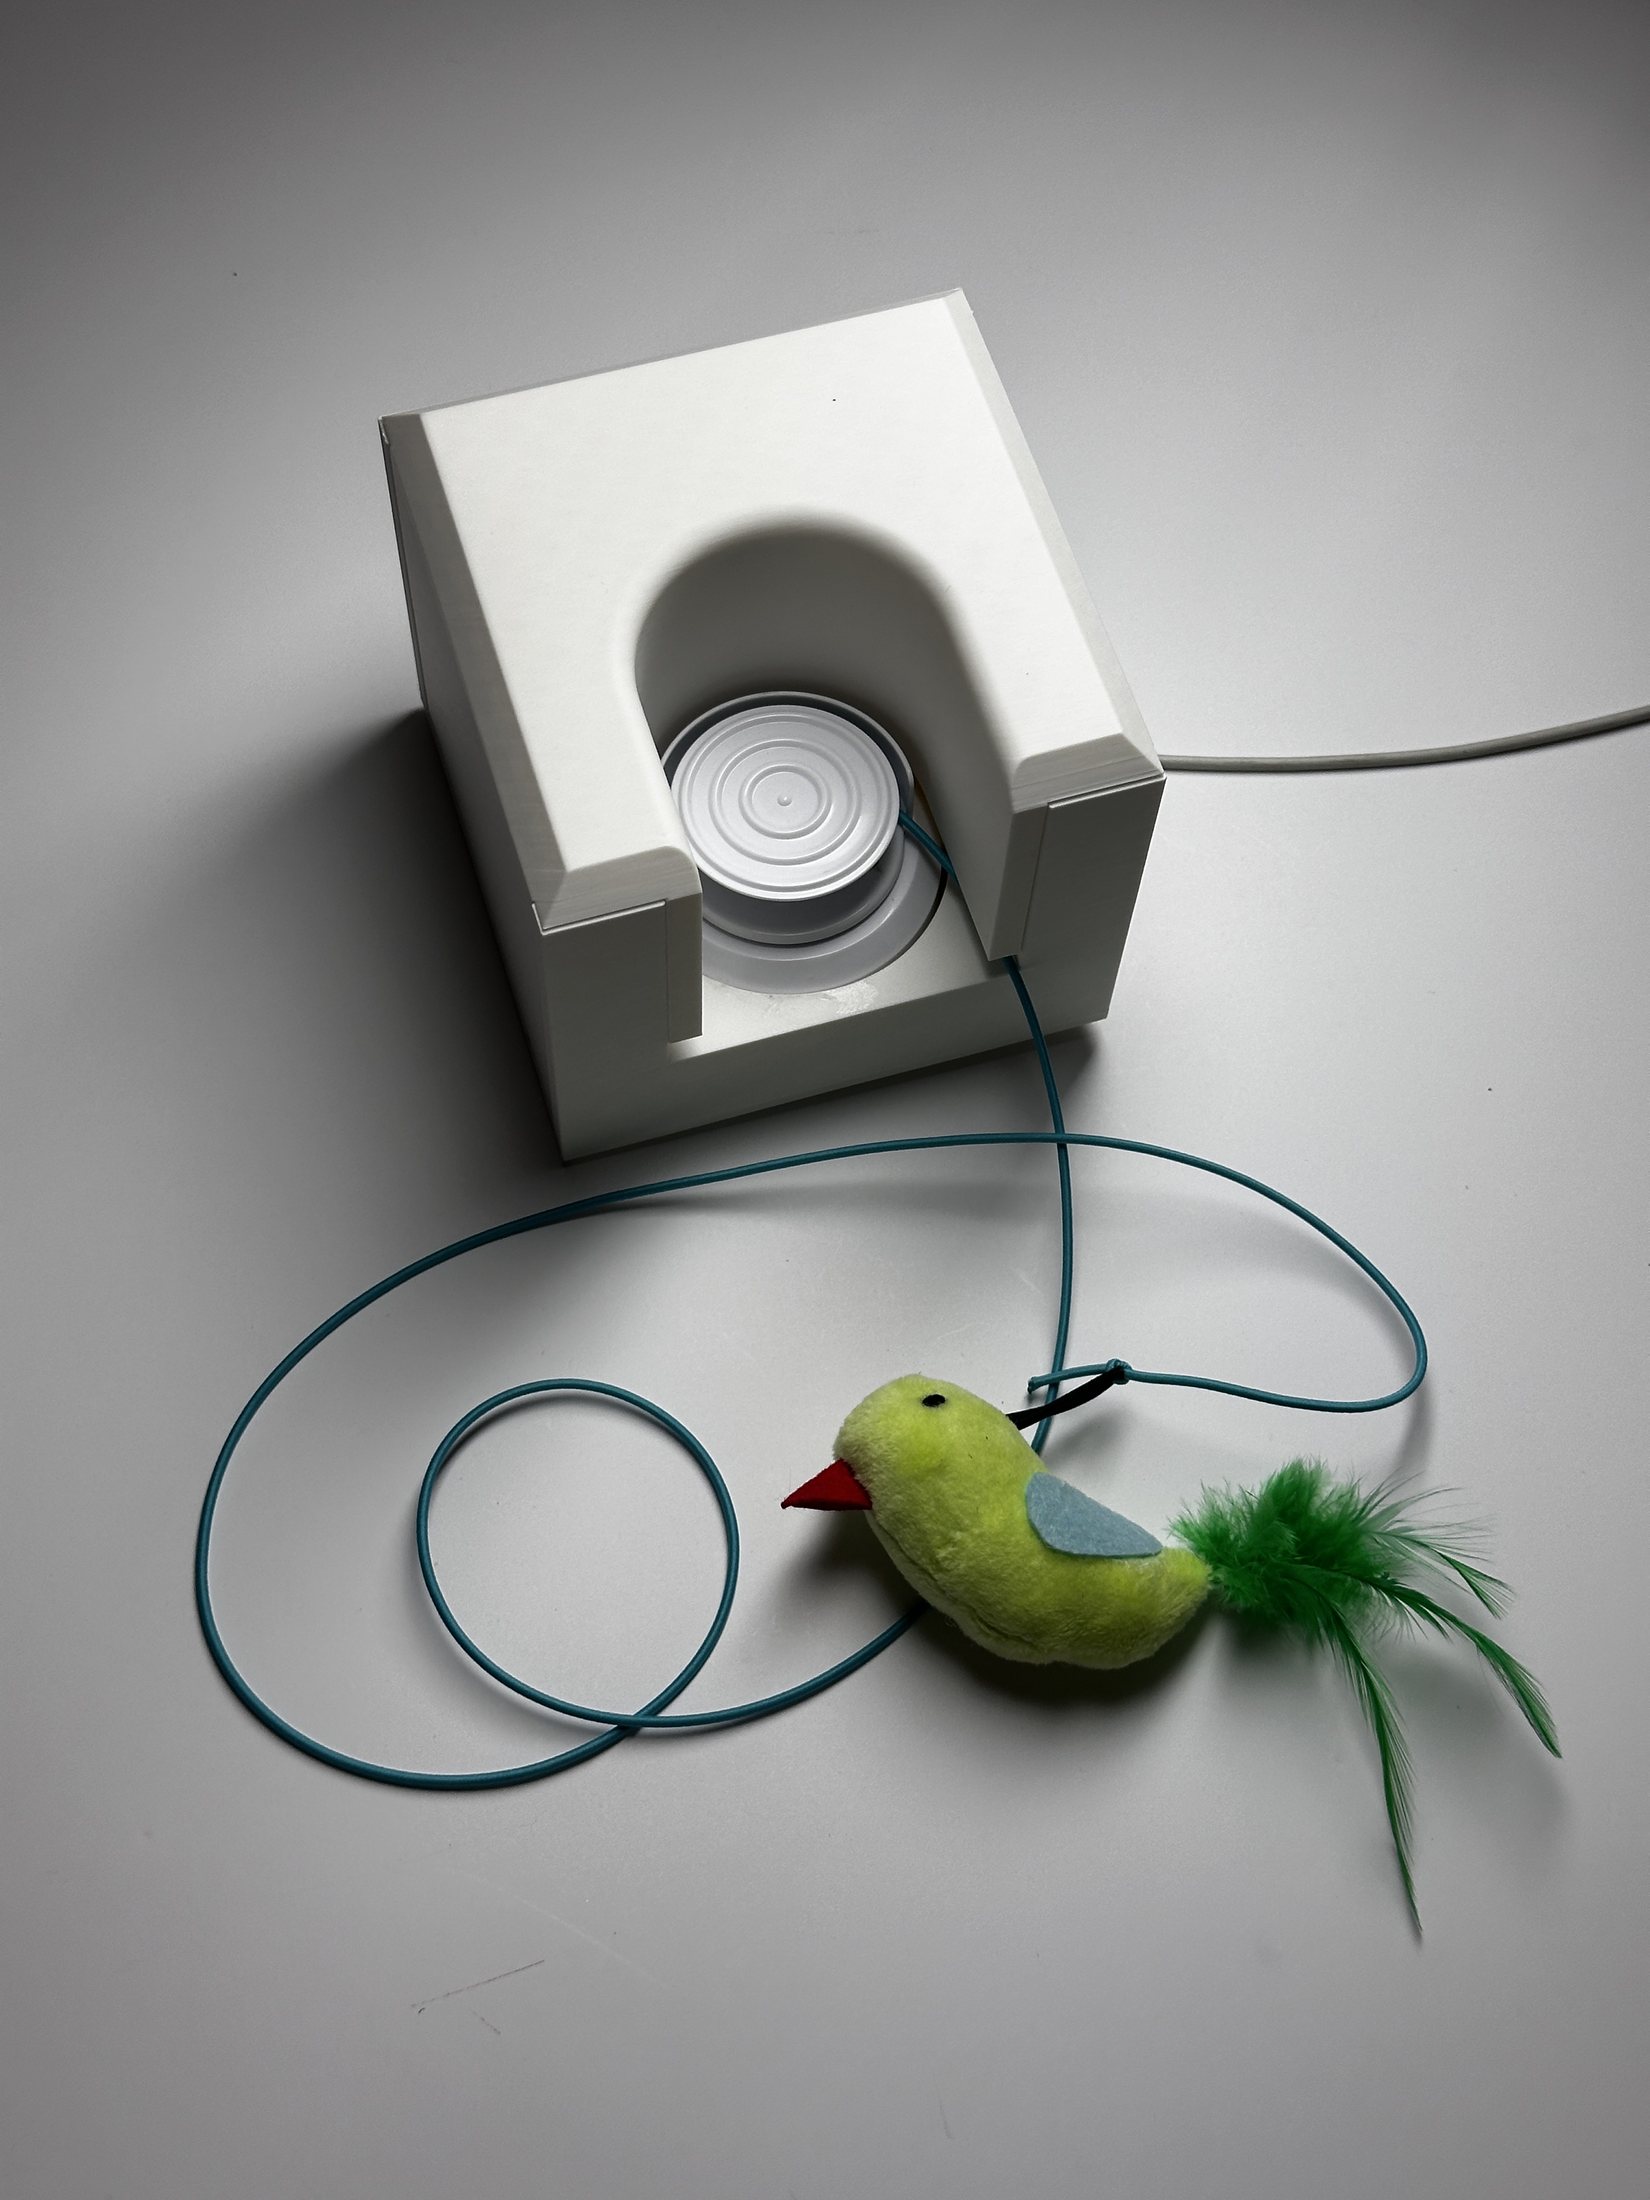
CHASE + CAPTURE + KILL A wall module releases a soft bird on an elastic cord. The graspable target, vibration, and pulling motion were intended to give the cat something physical to hold at the end of the sequence.
FIG 09 · RENDER
FIG 09 — WALL MODULE + ELASTIC PREY CORD
FIG 10 · PROTOTYPE
FIG 10 — RELEASE AND RETRACTION MECHANISM
FIG 11 · IN USE
FIG 11 — FINAL PREY INTERACTION NEAR THE FLOOR
SEC 05
Prototype in Context系统成果
FIG 12 · APARTMENT FIT
FIG 12 — THE SYSTEM FITS AROUND EXISTING FURNITURE AND VERTICAL CAT TERRITORY
A PRODUCT FAMILY AT HOME
Shared color, different forms, one room.
Pale enclosures connect the three objects visually; the soft surface, open track, and hanging prey make their different interactions legible. The apartment installation shows how the prototypes sit alongside existing furniture, with power cables still visible.
SPACEWINDOW · WALL · FLOOR EDGE
BEHAVIOR5 STAGES · 3 DEVICES
BUILDFDM · SERVO · SOFT GOODS
WHAT TO EVALUATE NEXTThe clips document short interactions with the working prototypes. Longer observation would be needed to evaluate sustained engagement, reset and maintenance effort, and unattended operation.